Engineering Next-Generation Counter-UAS Antenna Arrays
Engineering Next-Generation Counter-UAS Antenna Arrays
The rapid proliferation of Unmanned Aerial Systems (UAS)—ranging from commercial micro-drones to highly coordinated, militarily sophisticated autonomous swarms—has radically altered the modern security landscape. As asymmetric threats escalate across civil infrastructure, commercial airspace, and active combat theaters, traditional kinetic defense mechanisms prove insufficient, costly, and behaviorally hazardous. The modern frontline of defense has fundamentally transitioned to the electromagnetic spectrum. At the absolute center of this paradigm shift are advanced Counter-UAS (C-UAS) antenna systems.
Here is an in-depth technical analysis of how modern C-UAS antenna arrays are designed, built, and deployed to neutralize airborne threats.
1. The C-UAS Electromagnetic Challenge
To neutralize an incoming drone without physical kinetic impact, a C-UAS system must execute two primary tasks: passive detection (RF sensing) and active mitigation (electronic jamming or spoofing). Doing so requires an antenna architecture that can navigate an incredibly complex radio frequency (RF) environment.
Modern threats operate across an increasingly broad and agile spectrum. While commercial off-the-shelf (COTS) drones historically dominated the ISM bands (2.4 GHz and 5.8 GHz), modern military-grade and customized asymmetric threats operate anywhere from very low UHF/VHF frequencies (for long-range control lines) up to X-band and K-band frequencies for ultra-wideband data pipelines. Furthermore, the antenna system must maintain a high signal-to-noise ratio (SNR) when tracking a target with a radar cross-section (RCS) smaller than 0.01m^2 moving at extreme velocities.
Key Engineering Constraint: Friis Transmission Physics
The fundamental math governing C-UAS mitigation relies on overpowering the control signal received by the drone from its operator. The jammer must inject a power density at the drone's receiver that drastically exceeds the legitimate signal power. This relationship is bound by the Friis Transmission Equation, where received power (Pr) scales inversely with the square of distance (R^2):
Pr = Pt Gt Gr (lambda/4 pi R)^2
To defeat a drone close to its operator from a long-range defensive stand-off position, the C-UAS antenna gain (Gt) must be dynamically maximized via tight, highly focused beams.
2. Antenna Architectures in C-UAS Systems
No single antenna topology fits every operational profile. Engineers must deploy a hybrid blend of directional, omnidirectional, and phased-array systems tailored to specific deployment vectors (fixed infrastructure, mobile vehicular, or man-portable/dismounted).
A. Omnidirectional Antennas (Situational Awareness)
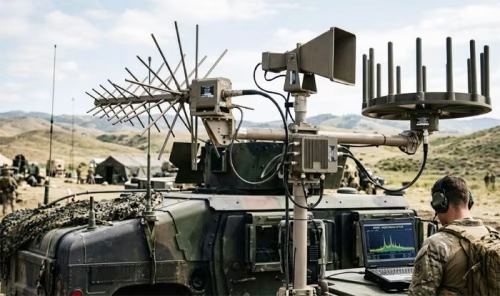
Typically utilized for initial detection and localized, close-in bubble defense. Topologies like biconical, collinear, and discone antennas offer a full 360 degrees azimuth coverage. While crucial for continuous environmental scanning, they suffer from inherently low gain (typically 2dBi to 6dBi), making them highly susceptible to environmental multipath interference and power dilution when executing electronic mitigation. For more details please visit Tactical Long Range Counter-UAS UAV Antennas and Military-Grade GPS Jammer & Anti-Jam Antennas
B. High-Gain Directional Antennas (Targeted Neutralization)
To punch through electronic counter-countermeasures (ECCM), high-gain directional systems are deployed. Common choices include log-periodic planar arrays, helical antennas, and horn antenna clusters. Helical antennas are highly valued in C-UAS applications because they inherently produce Circular Polarization (CP). Because a spinning, tumbling, or banking drone constantly changes its antenna polarization relative to the ground station, utilizing Circular Polarization prevents the devastating 3dB polarization mismatch loss that linear antennas experience. For more details please visit High-Performance Circular Polarized Helical Antennas and High-Gain Directional GPS Antennas (L1 & L2 Bands)
C. Active Electronically Scanned Arrays (AESAs) & Phased Arrays
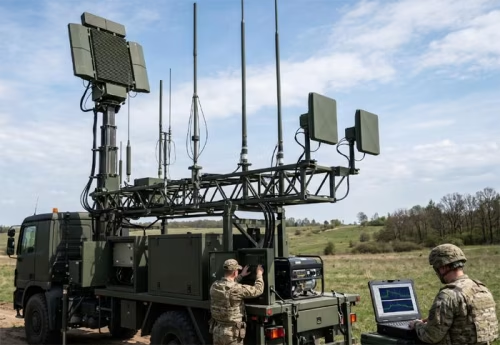
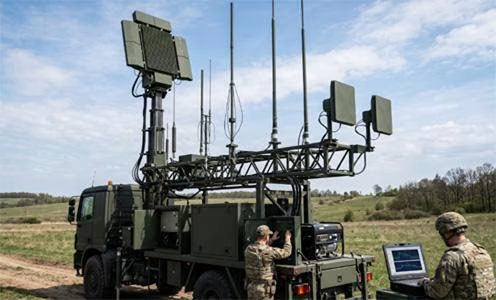
The gold standard of modern C-UAS architecture is the AESA. By altering the phase shift between dozens or hundreds of individual microstrip patch antenna elements, the system can steer a highly focused RF beam in microseconds without any mechanical movement. This is critical for defending against coordinated swarm attacks, where a mechanical gimbal antenna would simply fail due to the physical inertia limits of tracking multiple split targets.
3. Spectrum Coverage and Frequency Band Analysis
A modern C-UAS antenna suite must be robustly ultra-wideband (UWB) or heavily multiband. The table below outlines the core operational frequency spectrum and the matching antenna design requirements implemented by tier-one defense integrators:
| Frequency Band | Target Drone System / Signal Type | Antenna Design Requirements & Challenges |
|---|---|---|
| UHF / VHF (433 / 868 / 915 MHz) | Long-range telemetry, proprietary custom control links, FPV video streams. | Requires physically large elements. High mutual coupling challenges when arrays are tightly packed. |
| S-Band (2.4 GHz) | Standard commercial Wi-Fi/Bluetooth control, custom digital links. | Extreme congestion from civil infrastructure. Requires highly selective bandpass filtering and narrow beam widths. |
| C-Band (5.1 – 5.8 GHz) | Ultra-low latency analog/digital FPV video feeds, modern high-throughput telemetry. | Atmospheric attenuation and rain fade considerations. Requires precise phase matching across elements. |
| X & Ku Bands (8.5 – 18 GHz) | Military localized precision navigation radars, ultra-wideband satellite uplinks. | Micro-precision tolerances required in microstrip etching. High path loss dictates high-density AESA topologies. |
| GNSS Bands (L1, L2, L5) | GPS, GLONASS, Galileo, BeiDou localization signals (Target for spoofing/denial). | Requires high gain toward the horizon to disrupt reception, combined with controlled nulls to protect friendly assets. |
4. Advanced Innovations: Cognitive RF and Metamaterials
As drone technology moves toward fully autonomous, non-RF-emitting operational modes (such as optical edge-AI navigation and inertial guidance), the requirements placed on C-UAS antennas have evolved beyond raw power output.
- Metamaterial Electronically Scanning Arrays (MESAs): Traditional AESAs require expensive, power-hungry Phase Shifters and Transmit/Receive (T/R) modules for every element. MESAs utilize a software-controlled metamaterial structure to dynamically tune the refractive index across the antenna surface. This achieves ultra-fast beam steering at a fraction of the cost, weight, and power consumption—enabling tactical integration on light tactical vehicles.
- Digital Beamforming (DBF) & Cognitive Sensing: By routing the digitized signal directly from individual element ADCs, modern C-UAS processors can synthesize multiple independent beams simultaneously. A cognitive C-UAS antenna array can execute passive signal surveillance on Beam A, track an identified hostile threat on Beam B, and inject a localized GPS spoofing mask on Beam C—all within the exact same aperture array.
- MIMO-Enhanced Spatial Filtering: Utilizing Multiple-Input Multiple-Output (MIMO) spatial multiplexing allows defensive systems to separate close-proximity drone targets from background environmental clutter (like urban reflections or avian movement), significantly decreasing false-alarm rates in high-clutter environments.
5. The Horizon: Preparing for Autonomous Swarms
The ultimate evolutionary test for C-UAS antenna systems is the localized saturation attack. When dozens of autonomous drones attack concurrently from multiple vectors, traditional sequential defense structures fail.
The future belongs to highly dense, low-profile, multi-layered flat panel phased arrays distributed across tactical surfaces. These systems utilize machine-learning-driven beam management algorithms capable of distributing localized electromagnetic nulls and peak energy pulses in nanosecond cycles. For RF engineers and defense contractors, the mandate is clear: the efficacy of any Counter-UAS solution lives and dies at the physical layer. The antenna is no longer just a passive transducer; it is the highly dynamic, software-defined tip of the spear in electronic warfare.
How Counter UAS Systems Works
A Counter-UAS (Counter-Unmanned Aerial System) or C-UAS works as a multi-layered security ecosystem designed to detect, track, identify, and neutralize unauthorized drones or autonomous aerial threats.
Because modern drones can be small, fast, and operate autonomously, a successful C-UAS solution cannot rely on a single technology. Instead, it follows a strict operational sequence often referred to as the "Kill Chain" or "Mitigation Chain": Detect ----- Track ----- Identify ----- Neutralize.
Phase 1: Detection and Tracking (Finding the Threat)
Before a drone can be neutralized, it must be discovered. C-UAS systems use a combination of active and passive sensors to scan the airspace, as no single sensor is perfect across all environments.
- Radio Frequency (RF) Sensors: These are passive antennas that scan the electromagnetic spectrum for the radio signals transmitted between a drone and its ground controller, or the drone's video downlink. They are highly effective because they can detect a drone the moment it is turned on—often before it even takes off.
- Radar (Radio Detection and Ranging): Unlike RF sensors, radar is active; it sends out radio pulses and measures the reflections. Specialized C-UAS micro-radars are tuned to detect objects with an incredibly small Radar Cross Section (RCS) and differentiate between a micro-drone and a bird based on flight dynamics and propeller modulation (micro-Doppler signatures).
- Electro-Optical and Infrared (EO/IR) Cameras: Once an RF sensor or radar flags a target's coordinates, optical and thermal cameras slew to that position. Optical cameras provide visual validation during daytime, while infrared (thermal) cameras detect the heat signatures emitted by the drone’s motors and batteries at night.
- Acoustic Sensors: Microphones and acoustic arrays "listen" for the distinct audio frequencies produced by drone propellers. While limited in range (usually under 300–500 meters) and sensitive to urban background noise, they provide an excellent final line of defense in complex environments.
Phase 2: Identification (Friend or Foe)
Once an object is detected, the system's software analyzes its telemetry, speed, and signature. This phase prevents false alarms (such as targeting a bird) and ensures that friendly assets (like commercial aircraft or friendly police drones) are not accidentally neutralized. Advanced software uses AI and machine learning to match the detected RF signature against an updated library of known commercial and military drone profiles.
Phase 3: Neutralization / Mitigation (Defeating the Threat)
Once a target is confirmed as a hostile or unauthorized UAS, the system deploys a mitigation mechanism. These mechanisms are broadly categorized into Soft-Kill (electronic/cyber) and Hard-Kill (physical destruction) methods.
A. Soft-Kill / Electronic Mitigation (Non-Kinetic)
Electronic solutions are the most common because they minimize collateral damage, making them ideal for airports, urban environments, and critical infrastructure.
- RF Jamming: The C-UAS antenna blasts high-power directional radio energy at the exact frequencies the drone uses to communicate with its operator (typically 2.4 GHz, 5.8 GHz, or specialized UHF bands). By overpowering the legitimate control signal, the drone loses connection. Depending on its programming, the jammed drone will either execute a controlled vertical landing, attempt to return to its launch point, or drift away.
- GNSS/GPS Spoofing: The system transmits fake satellite navigation signals to the drone. By feeding the drone incorrect coordinates, the C-UAS can trick the drone into thinking it is in a "No-Fly Zone," forcing it to land, or misdirect it away from the protected airspace.
- Cyber Takeover (Protocol Manipulation): Instead of using raw power to jam the drone, advanced systems intercept the drone’s digital signal, crack its encryption, and inject command overrides. This allows the security operator to completely hijack the drone, commanding it to fly to a safe recovery zone while downloading its telemetry data.
B. Hard-Kill / Physical Mitigation (Kinetic)
In high-threat military environments or situations where autonomous drones are flying via pre-programmed GPS-independent waypoints (making jamming ineffective), physical destruction is required.
- Net Guns and Interceptor Drones: Friendly "hunter" drones can be launched to track the rogue drone and fire a physical net over its propellers, bringing it down or carrying it away.
- High-Energy Lasers (HEL): Directed-energy laser weapons focus an intense beam of light on the drone, physically burning through its plastic chassis, blinding its optical sensors, or melting its internal electrical circuitry within seconds.
- High-Power Microwave (HPM): An HPM system fires a massive burst of electromagnetic energy that instantly fries the microelectronics inside any drone within its arc. HPM systems are uniquely suited for neutralizing entire drone swarms simultaneously because they project a wide, conical blast rather than a single pinpoint beam.
- Kinetic Projectiles: Automated guns, specialized shotguns, or programmable airburst ammunition can be used to physically destroy the target mid-air.
The Command and Control (C2) Core
The true brain of a C-UAS is its Command and Control (C2) software. The C2 system acts as a central platform that ingests data from the radar, RF sensors, and cameras simultaneously (a process called sensor fusion). It presents a single, unified airspace map to security personnel and automatically suggests the most effective, lowest-risk mitigation method based on the drone's speed, distance, and vector.